Introduction
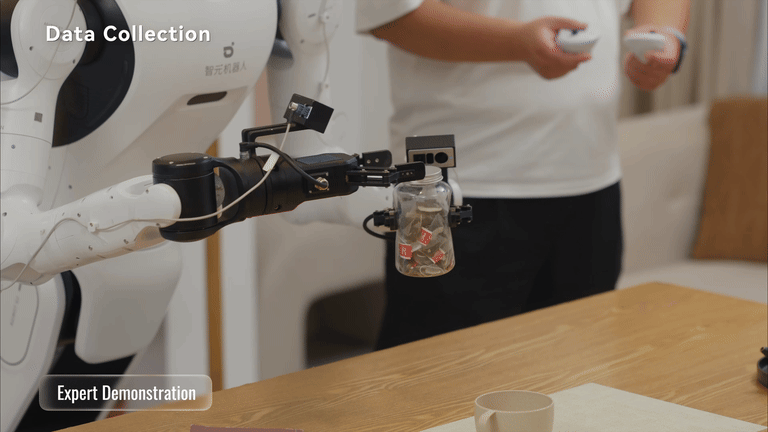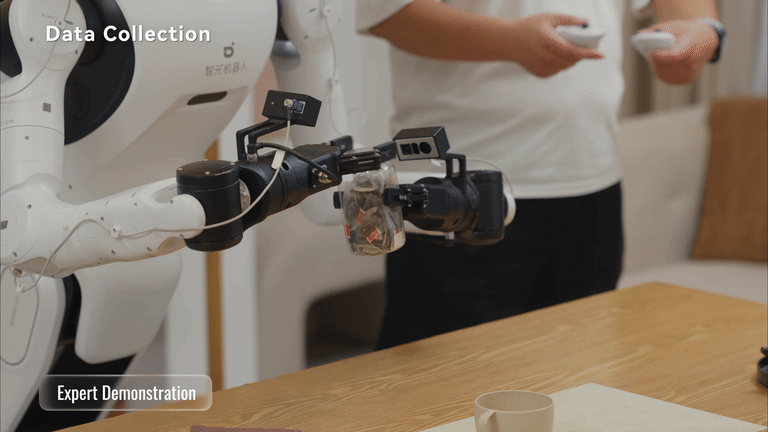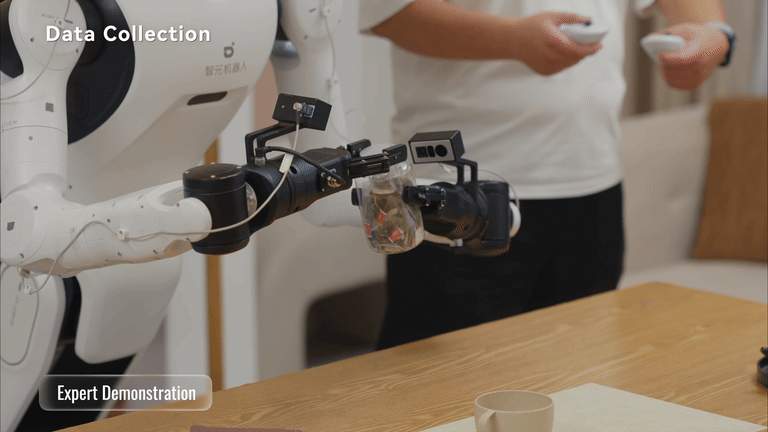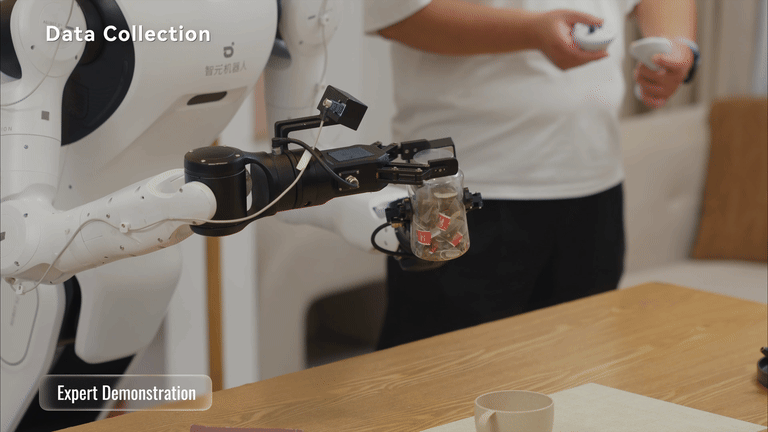
AGIBOT released GE-Act 2.0 in September. The model is trained from random initialization on embodied manipulation data instead of starting from an existing pretrained video-generation model.
AGIBOT says zero-shot evaluation covers 100 atomic tasks, 20 skill categories and two robot embodiments. Test scenes include unseen backgrounds, lighting and object instances.
Information verified from official sources available as of September 14, 2026.
Training from scratch isolates the robot-data experiment
Pretrained video models carry knowledge from large internet datasets. GE-Act 2.0 removes that starting point in the experiment described by AGIBOT.
That setup makes it easier to study how robot-data scale relates to manipulation performance. Data composition and evaluation rules still need close inspection.
Zero-shot needs a strict definition
AGIBOT says the same model is evaluated without task-specific fine-tuning or added demonstrations.
Per-task results are more useful than one average because failures can cluster around contact-heavy tasks, precise placement or long action sequences.
Reproducibility comes next
An open evaluation set plus fixed reset rules would make outside comparisons easier.
For production use the next metrics are cycle time, recovery after failed grasps and intervention frequency across long runs.
Limitations and missing information
- Performance claims are from AGIBOT's own release.
- Zero-shot results depend on how training and test distributions are separated.
Conclusion
Outside replication should keep trial counts and reset rules visible so the scaling claim can be tested on matched tasks.
Sources and methodology
Share this article
Share the current TechniaHQRobot article page.
Continue reading
Open the latest robotics reporting, Physical AI analysis and hardware notes.