Introduction
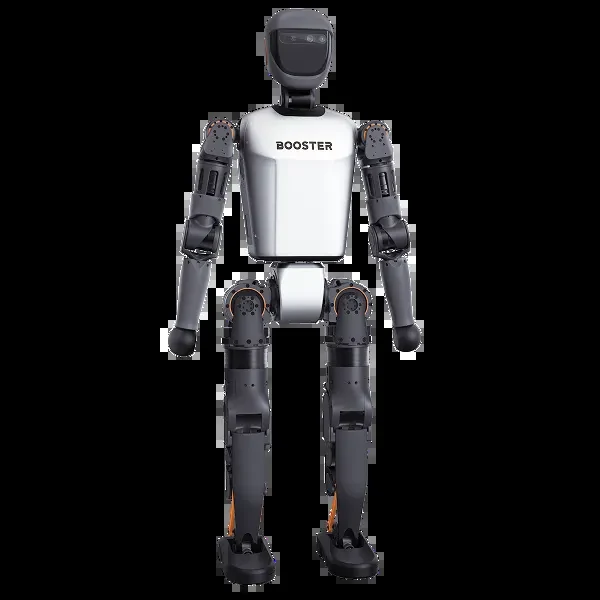
A September 3 paper introduces BRIDGE. It is an 88 cm open-source humanoid built from a morphology-control co-design process.
The authors optimize body design against two goals. One measures how well human motion can be retargeted to the robot. The other measures whether the robot can track that motion dynamically.
Information verified from official sources available as of September 14, 2026.
Robot proportions change the learning problem
Human motion data does not map cleanly onto every humanoid. Limb lengths, joint limits and mass distribution can force large corrections during retargeting.
BRIDGE treats those hardware choices as variables in the design loop and compares its metrics with Bumi, K1 and Toddlerbot baselines.
Open hardware supports outside replication
The platform is released with its control policy. Research groups can test locomotion, balance and dynamic maneuvers on a common body and control stack.
Build tolerances, actuator sourcing and calibration can still change tracking quality between labs.
Task-level tradeoffs should stay visible
Walking, squatting, reaching and recovery use different contact patterns and joint ranges.
Reporting those motions separately can show where morphology-control co-design gives its largest gains.
Limitations and missing information
- The reported comparisons come from the paper authors.
- Replication quality can vary with mechanical build and calibration.
Conclusion
BRIDGE gives researchers a concrete platform for measuring how body design changes motion retargeting and control quality.
Sources and methodology
Share this article
Share the current TechniaHQRobot article page.
Continue reading
Open the latest robotics reporting, Physical AI analysis and hardware notes.